


Primary sourceArtifact1965
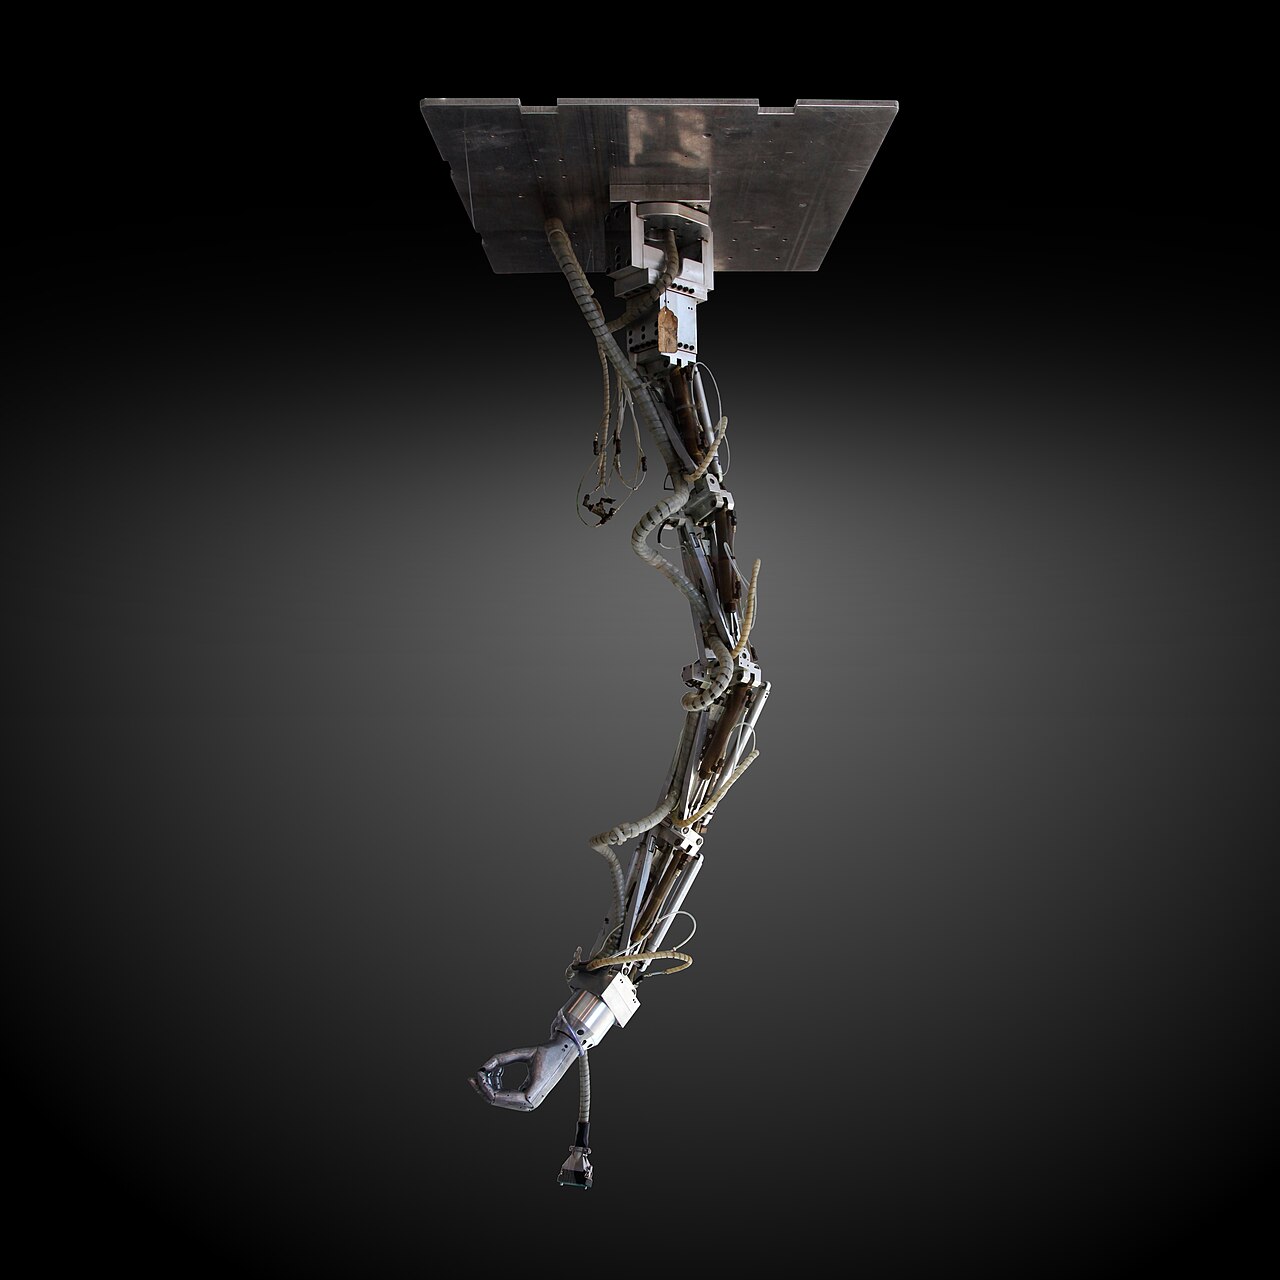
Minsky's Tentacle Arm
1965
A hydraulic, multi-jointed robot arm built under Minsky's direction at the MIT AI Lab, now preserved at the MIT Museum.
Minsky led the MIT AI Lab research that produced this robot arm, showing his work in hands-on robotics.
About this source
What it is
This is a surviving robot arm built in 1965 at the MIT Artificial Intelligence Lab, designed to reproduce the movement of a human arm. It is a hydraulic, multi-jointed device, now held by the MIT Museum.
Why it matters
The arm reflects the hands-on robotics research that Marvin Minsky led at MIT, showing that his vision of artificial intelligence was not purely theoretical but included building physical machines that could sense and move in the world.
Look closer
- What does the design of the arm suggest about how engineers in the 1960s imagined replicating human movement?
- Why might a research lab build a physical robot instead of only writing computer programs?
- What limitations might this early robot arm have had compared to a human arm?
This artifact is part of the curated material that grounds the AI version of Marvin Minsky on Humy.ai — when students ask about related events, the AI can quote it and cite it.
More Marvin Minsky sources
Browse all 15 → Document
Primary source
A Proposal for the Dartmouth Summer Research Project on Artificial Intelligence
John McCarthy, Marvin Minsky, Nathaniel Rochester, Claude Shannon · 31 August 1955
 Document
Primary source
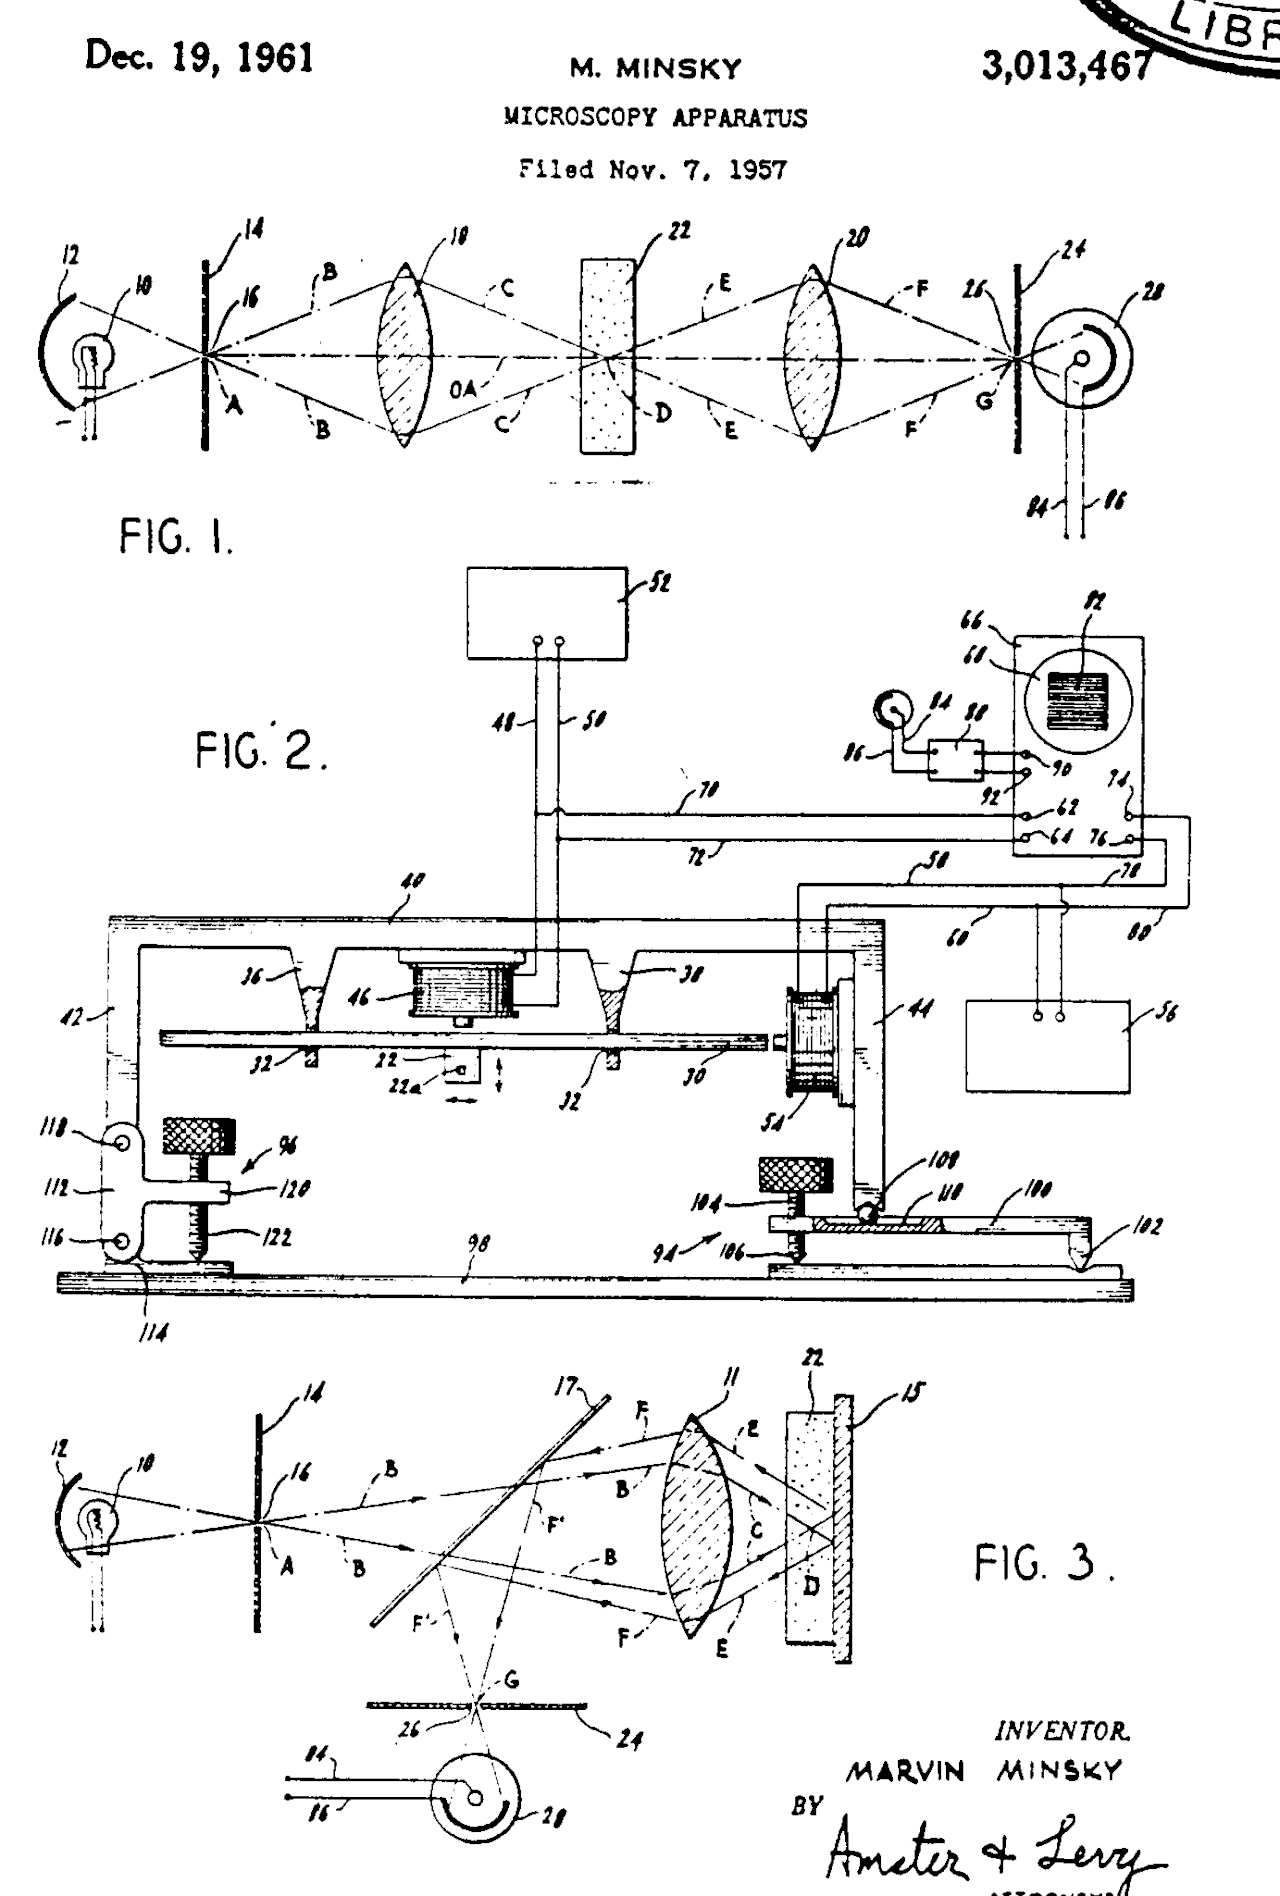
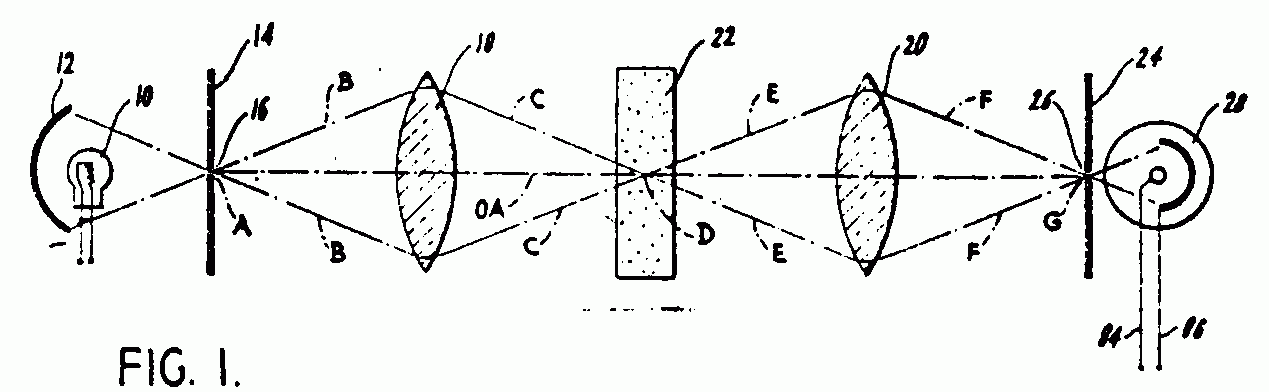
Patent for a Confocal Microscope
Marvin Minsky · filed 7 November 1957, issued 19 December 1961
 Photograph
Secondary source
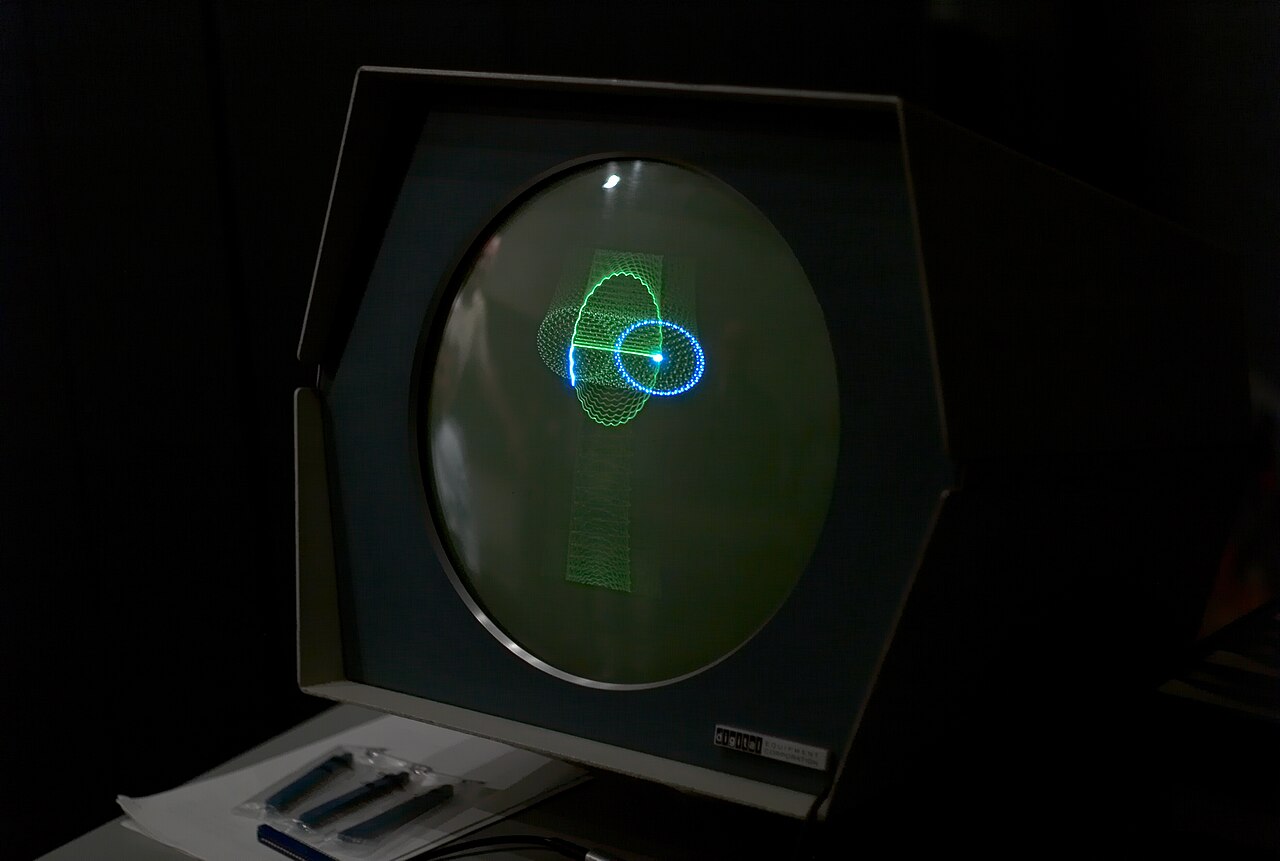
Minskytron Running on a Restored PDP-1
Joi Ito · 2007
 Photograph
Primary source
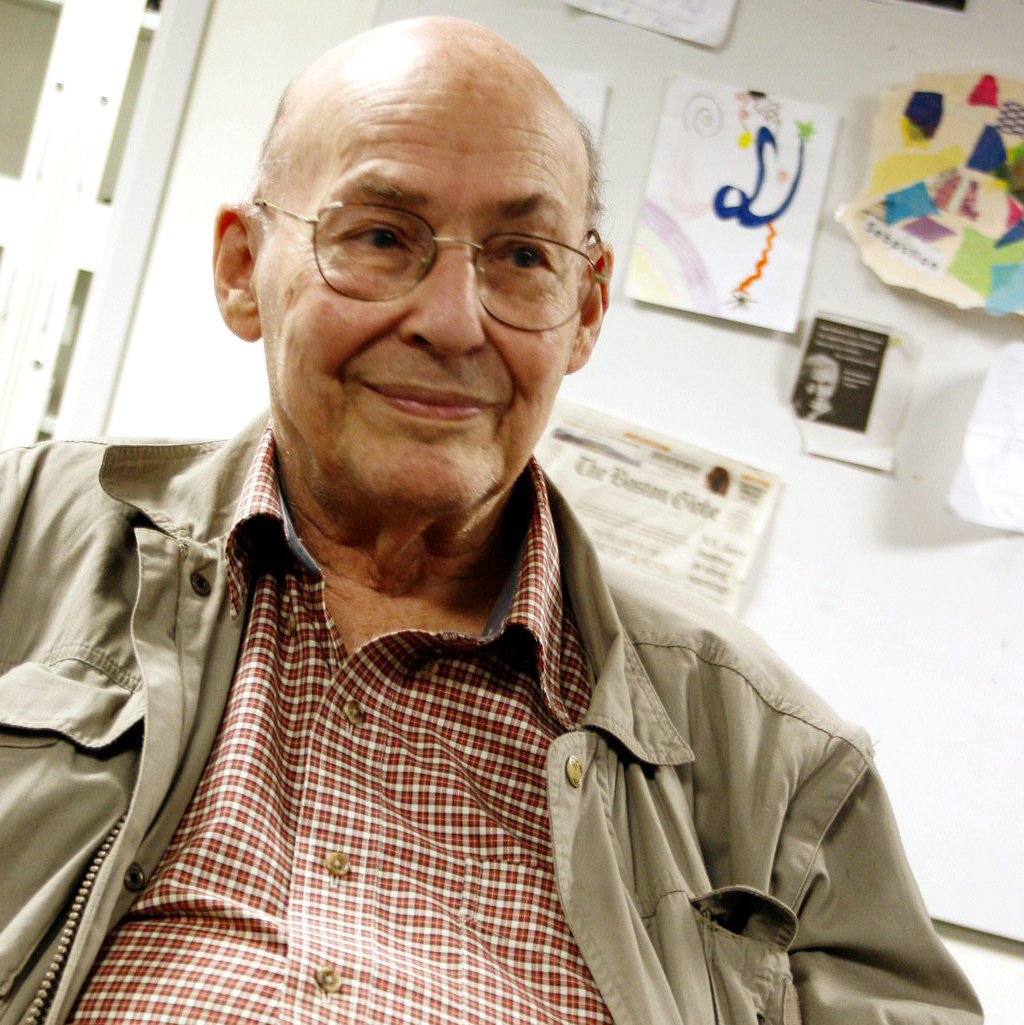
Marvin Minsky at OLPC
Sethwoodworth
Free account
Read every Marvin Minsky source
Sign up free →
Ready when you are
Start chatting with Marvin Minsky now.
20 messages free · No credit card · Available in 50+ languages.